Propeller imbalance is the most common source of vibration in a multirotor or fixed-wing UAV, and it is also the cheapest to eliminate. The propeller selection guide covers how to choose diameter, pitch, blade count and material for a mission profile; this guide covers what happens after the propeller is chosen, how to specify its balance, measure the vibration it produces, and correct it in the field and at the factory. It sits alongside the propulsion testing and validation guide, which covers the thrust-stand and endurance testing that a complete propulsion system should pass before deployment.
Why propeller imbalance is a system problem, not a spinning part problem
Imbalance converts rotational energy into a sinusoidal force at the propeller's rotational frequency, and that force propagates through the motor mount into the airframe. The magnitude scales with the square of the rotational speed: the same residual imbalance that produces a barely measurable buzz at 2,000 RPM produces a destructive force at 6,000 RPM. For a two-blade propeller at 6,000 RPM the fundamental frequency is 100 Hz. Right in the range where a carbon fiber arm's first bending mode lives (typically 80–150 Hz for a 650 mm quadcopter arm, as the motor topology guide notes in its torque-ripple discussion). When the two coincide, the airframe amplifies rather than attenuates the vibration.
The system-level costs are measurable. The IMU sees the vibration as attitude noise, which degrades position hold and increases the correction effort the flight controller must apply, the safety and redundancy guide explains why a saturated IMU is a failure mode, not a nuisance. The camera and gimbal see it as image blur and servo wear. The motor sees it as accelerated bearing wear, and the ESC sees it as current ripple from the motor fighting the oscillation. Every one of those components has a vibration specification in its datasheet, and propeller imbalance is the single most likely reason the airframe exceeds them.
Static balance vs dynamic balance: which one your propellers actually need
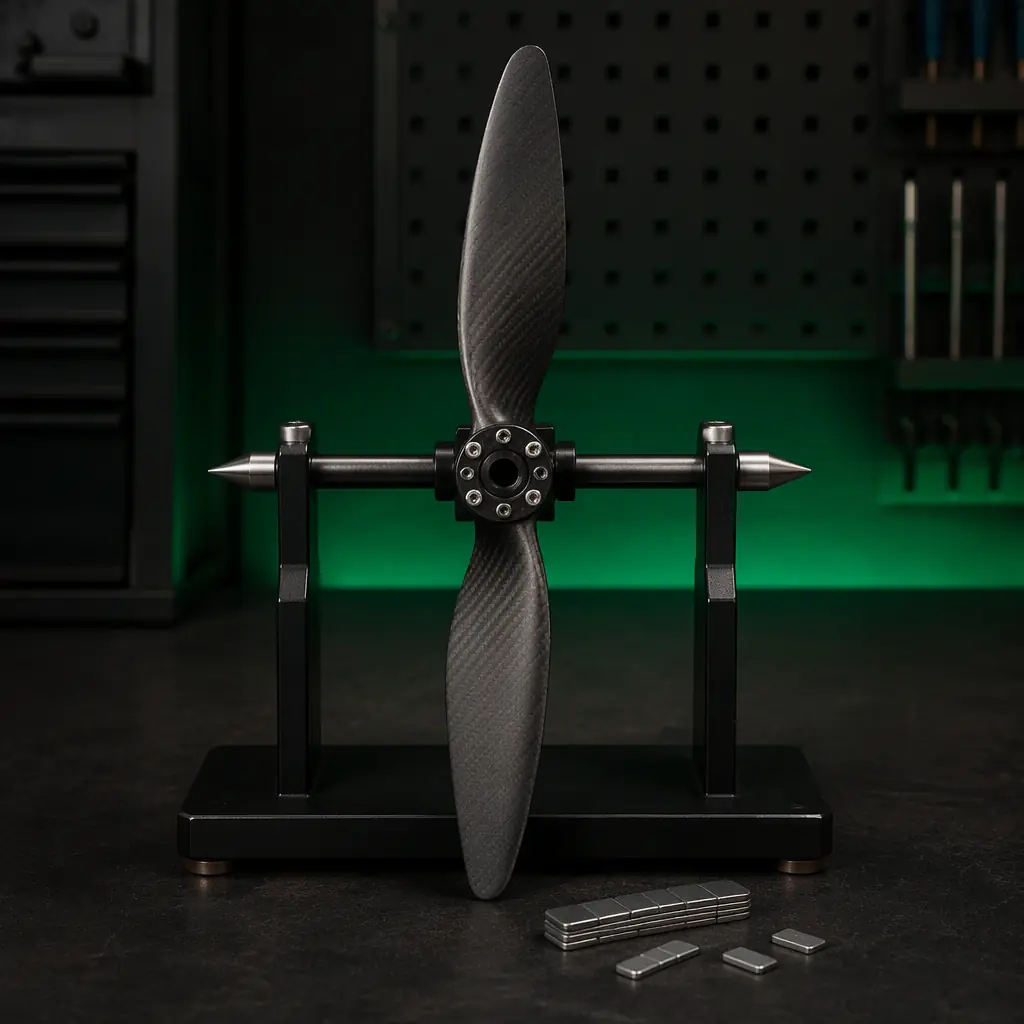
Balance comes in two forms, and the distinction decides what test equipment you need. Static balance is the center-of-gravity test: the propeller is placed on horizontal knife edges or a magnetic balancer, the heavy blade rotates to the bottom, and material is removed from (or added to) the light blade until the propeller rests in any position. Static balance removes the out-of-plane mass asymmetry but says nothing about how the mass is distributed along the hub axis.
Dynamic balance is the in-plane test: the propeller is spun on a balancing machine that measures the vibration at two bearing planes and computes the correction required in each plane. A propeller can pass static balance and still be dynamically unbalanced: for example, when both blades have equal mass but the mass is distributed differently along the span, producing a couple that only appears at speed. For a small UAV propeller the practical rule is simple: static balance is sufficient for propellers under roughly 250 mm diameter; dynamic balance is required above that, and for any propeller on a precision platform (mapping, survey, inspection) regardless of size. The mapping and survey components guide is the reference for why precision platforms are the demanding case: a centimetre-level RTK solution is meaningless if the IMU is vibrating through its noise floor.
 Concept illustration
Balance grades: what G2.5 and G6.3 mean for a UAV propeller
The ISO 1940-1 standard defines balance quality grades by the product of residual specific unbalance and rotational speed, the quantity G, expressed in millimetres per second. The relevant grades for propellers and rotors are G6.3 (typical for production propellers, fans and rotors with no special requirement) and G2.5 (for rotors with strict requirements, grinding machine spindles, aircraft propellers, and precision rotating assemblies). The residual eccentricity allowed at a given speed is e = G × 1000 / ω, where ω is the rotational speed in radians per second. At 6,000 RPM, ω = 628 rad/s, so G6.3 permits a residual center-of-gravity offset of about 10 µm and G2.5 permits about 4 µm.
Those numbers translate into procurement language. A 24-inch (600 mm) carbon fiber propeller of 25 grams balanced to G2.5 at 6,000 RPM carries a residual unbalance of roughly 0.1 g·mm. Below the resolution of most workshop scales, which is exactly why factory balance data matters more than a visual inspection. Nylon injection-molded propellers come out of the mold with blade-to-blade mass variation of ±3% in a production lot, as the propeller selection guide documents, and need post-molding balancing to reach a usable grade; carbon fiber propellers with consistent layup achieve ±0.5% and hold G2.5–G6.3 depending on the manufacturer's QC. When a supplier states a balance grade, ask for the test method and the per-unit data. A grade without a measurement report is a marketing claim.
Measuring vibration: from IMU logs to a balancing rig
Before balancing propellers, measure the vibration baseline. The aircraft's own telemetry is the cheapest instrument you already own. ArduPilot and PX4 log the IMU accelerometer at the full gyro rate; the ArduPilot vs PX4 guide covers the stacks, and both record the data you need. The procedure: hover the aircraft at cruise throttle in calm conditions, download the log, and inspect the FFT of the accelerometer axes. A sharp peak at the propeller rotational frequency (for example 100 Hz at 6,000 RPM on a two-blade propeller) is imbalance; a peak at the blade-pass frequency (200 Hz for a two-blade propeller at 6,000 RPM, 400 Hz for a four-blade) is an aerodynamic or tracking issue; broadband noise is usually motor bearing or ESC-related.
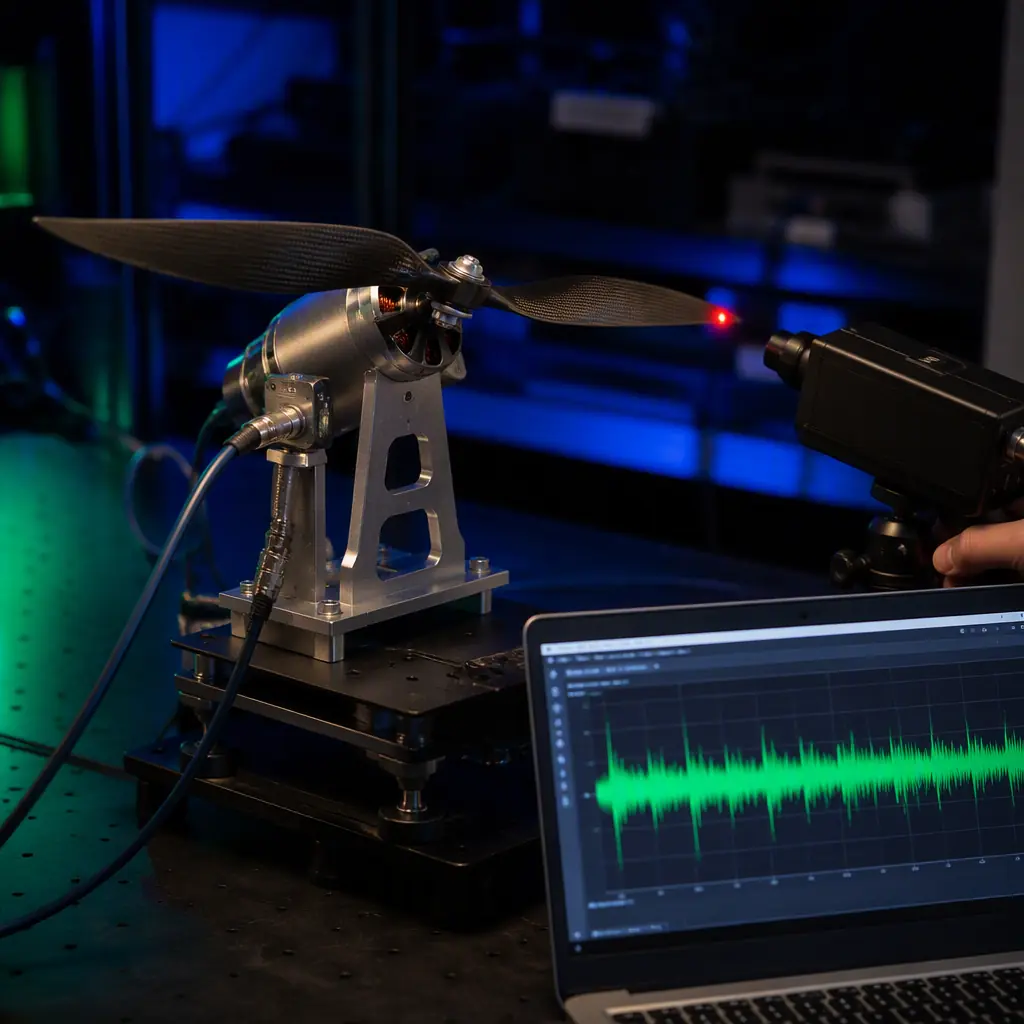
The acceptance threshold used by most flight controller vendors is vibration below 1 g RMS at the IMU, with 0.3–0.5 g as the target for smooth logs. If the baseline is above 1 g, or the rotational-frequency peak dominates the FFT, move to the bench: mount the motor on a thrust stand or rigid fixture, fit a calibrated accelerometer at the motor mount, and run the motor across the throttle range with a laser tachometer recording RPM. The propulsion testing guide describes the thrust-stand methodology this builds on. This measurement separates propeller imbalance from motor imbalance: spin the motor with no propeller and record the floor, then add the propeller. The delta at the rotational frequency is the propeller's contribution.
 Concept illustration
Where imbalance comes from: manufacturing, erosion, repair and mounting
Imbalance is not a binary defect; it is a property that drifts over the propeller's life, and a procurement team that treats it as a one-time factory check will be surprised by field results. The sources, in the order a propeller experiences them:
- Manufacturing. Mold parting lines, gate vestiges and inconsistent layup compression in composites create the initial imbalance. This is the source the balance grade covers. And the reason the acceptance test should be per-unit, not per-lot.
- Erosion and damage. Leading-edge erosion from particulate impact removes material unevenly, and the selection guide notes that erosion also triggers micro-cracks and UV degradation of the resin matrix. A propeller that was balanced at delivery can develop a gram-scale tip imbalance after a season of operations in dusty or sandy conditions.
- Repair and rework. Sanding, filling and re-tipping a damaged blade changes its mass distribution. Any repaired propeller must be rebalanced. And the repair itself should be documented, because the obsolescence management guide makes the broader point that field-modified components complicate the replacement and spares story.
- Mounting. The most common source of "imbalance" in the field is not the propeller at all: a collet that grips off-axis, a prop adapter with a bent shaft, a spinner that sits eccentrically, or debris under the mounting face. Always check the mounting hardware before rebalancing the propeller. The fix for a bent collet is a new collet, not tape on a blade.
- Moisture and temperature. Nylon absorbs moisture and changes mass and stiffness with humidity; composite propellers are far more stable. A nylon propeller balanced in a dry workshop can be measurably out of balance after a humid flight day, another argument for composite propellers on precision platforms.
Field balancing: the procedure that removes the last 90% of vibration
Factory balance gets a propeller to its grade; field balancing corrects the residual interaction of propeller, collet, motor and spinner as an assembly. The procedure that works in practice:
Step 1, static check. With the propeller off the aircraft, place it on a magnetic balancer or two knife edges. Mark the heavy blade (it rotates to the bottom), and add a small strip of tape to the light blade's tip or remove material from the heavy blade's back face, a few milligrams at a time. Repeat until the propeller rests at any angle. For a 24-inch carbon fiber propeller, the correction is typically 0.1–0.5 g.
Step 2, bench dynamic check. Mount the propeller and spinner on the motor, run up to cruise RPM on the instrumented fixture, and confirm the rotational-frequency peak dropped to the motor-only floor. If a peak remains at the rotational frequency with the propeller fitted but not without it, the residual is in the propeller/hub assembly, re-check the collet and hub runout first (a hub runout of 0.05 mm produces a significant imbalance force at 6,000 RPM), then re-balance the propeller as an assembly with the spinner fitted.
Step 3, in-flight verification. Re-hover and re-log the IMU. The acceptance criteria: the rotational-frequency peak is gone from the FFT, and overall vibration is below the 0.3–0.5 g target. Log the result per aircraft, because the fleet management guide shows how a per-aircraft vibration log turns a one-time fix into a maintenance trigger. When the vibration peak grows back, the propeller or its mounting has changed and it is time to inspect.
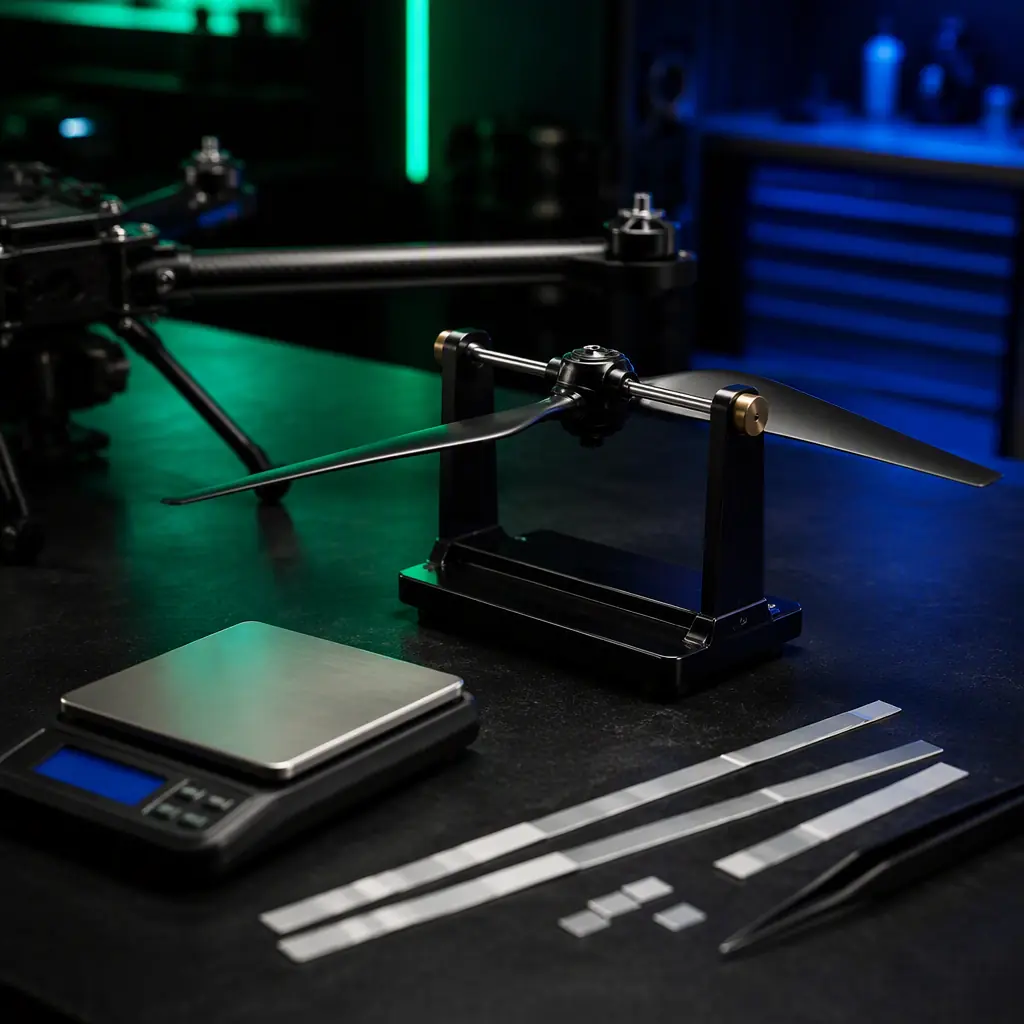 Concept illustration
Resonance and the vibration budget: coupling, modes and margins
Balance removes the forcing function; resonance decides whether the airframe amplifies what remains. Every airframe has structural modes, the first bending mode of a carbon fiber arm, the torsional mode of a folding arm latch, the mounting resonance of a gimbal or antenna mast, and the design discipline is to keep the propeller's rotational and blade-pass frequencies away from those modes across the operating throttle range. The motor topology guide gives the concrete example: a 3.36 kHz torque ripple from a high-ripple motor couples weakly into a 650 mm quadcopter whose arm modes sit at 80–150 Hz, but a 100 Hz propeller fundamental sitting directly on an arm mode is a different story.
The practical vibration budget has four layers: isolate (motor mounts and gimbal isolators with the correct durometer, the thermal management guide makes the related point that soft mounts also change heat paths, so the isolation choice is coupled to the thermal design), absorb (damping material on the arm, tuned mass dampers on the gimbal), filter (the flight controller's low-pass filters on the IMU, the sensor fusion guide covers the filtering architecture), and remove the source (balance the propeller). A propeller balanced to G2.5 removes the largest source; the other three layers then have a manageable input to work with instead of a saturated one.
The procurement specification: balance grade, measurement and acceptance
The specification that closes the loop with suppliers has five clauses, each with a verification method:
1. Balance grade. State the ISO 1940-1 grade per propeller size, G2.5 for propellers above 250 mm diameter and for precision-platform applications, G6.3 as the minimum acceptable for small production propellers. Verification: the supplier's per-unit balance report with the test RPM.
2. Balance test method. State whether static balance is acceptable (propellers under 250 mm) or dynamic balance is required (above 250 mm, and all precision-platform propellers). Verification: the test equipment description in the QC documentation, cross-checked against the electronics manufacturing quality guide for how QC documentation should be structured.
3. Blade-to-blade mass tolerance. State the maximum blade-to-blade mass difference per propeller size, ±0.5% for composite propellers on precision platforms, ±3% for nylon production propellers with post-molding balancing. Verification: the per-lot mass measurement data.
4. Acceptance testing. State the acceptance vibration threshold at the motor mount, below 1 g RMS at the IMU in hover, 0.3–0.5 g target, and the test procedure (motor-only floor vs propeller fitted). Verification: the test report from the propulsion testing program.
5. Field re-balance support. State whether the supplier provides balance data for replacement and repaired propellers, and the process for re-balancing repaired units. Verification: the repair and replacement documentation in the warranty and RMA terms.
The specification is only as good as the measurement it references. A procurement team that specifies G2.5 but accepts visual inspection has written a requirement it cannot verify; a team that specifies G2.5 and audits the balance report against its own bench measurement has closed the loop, and the supplier evaluation checklist is the framework for making that audit part of the vendor score.
Where propeller vibration comes from, by share of returns.
Vibration complaints arrive described as a propeller problem and usually are not one. In the units we see returned or re-balanced, the root cause divides across a small number of mechanisms, and only one of them is a manufacturing defect in the propeller itself. The table ranks them by share of returns and, more usefully, contrasts how each one behaves on a balancing rig against how it behaves once it is on an aircraft, because that difference is what makes field diagnosis slow.
| Source of imbalance | Share of returns | On the rig vs on the aircraft | Where it is fixed |
|---|---|---|---|
| Blade mass spread within a set | ~28% | Visible immediately on a static balancer; on the aircraft it appears as a constant once-per-revolution signature | Supplier sorting and pairing as matched sets, not random pairs |
| Hub and adapter runout or mounting error | ~24% | Rig shows a clean propeller; the aircraft shows vibration because the adapter is not concentric | Mounting interface: adapter runout measurement and a repeatable seating method |
| Blade erosion or tip damage in service | ~20% | Passes at delivery; the signature grows flight by flight | Operational: interval checks, blade replacement rather than field sanding |
| Residual dynamic imbalance after static balancing | ~16% | Static balancer reports zero; the two-blade couple only shows up when spun | Dynamic balancing, either at the supplier or in the field |
| Repair or re-finish shifting mass | ~8% | Balanced before repair; the re-balanced unit is not re-verified as a set | Repair process: mandatory re-balance and a new balance report per unit |
| Motor bell or shaft contribution misattributed | ~4% | Chasing the propeller never converges because the source is upstream | Diagnosis order: isolate motor, then hub, then blade |
Three of those six rows sit outside the propeller, and together they account for more than half of what gets reported as one. That is the practical reason to specify a matched set with per-unit balance data rather than a balance grade alone: a grade describes a single propeller against a tolerance, while the vibration a buyer experiences is produced by the whole rotating assembly. A pair of propellers individually inside G6.3 can still be a poor pair if their residual imbalances point the same way.
Two questions reduce this to something a purchase order can carry. Ask whether blades are supplied as matched sets with the pairing method stated, and ask what the adapter runout limit is and how it is measured. Both are cheap to answer, and both move the failure share in the table more than tightening the balance grade does.
Lead time, tooling and what changes with order size.
Propellers are the component where the gap between a prototype order and a production order is largest relative to unit cost, because so much of the work is setup: mould or mandrel, layup or injection parameters, and the balancing and pairing bench work that turns a batch into matched sets. Quoting a five-unit order and a five-hundred-unit order as the same product at different quantities misreads which cost is being paid.
| Order band | Tooling and setup share of unit price | Typical lead time | What changes at this volume |
|---|---|---|---|
| 1 to 5 units | Dominant, often more than half | 3 to 6 weeks | Each unit is individually balanced and paired; design and material changes remain open |
| 6 to 25 units | Moderate | 4 to 7 weeks | Balancing bench becomes a bottleneck; pairing is documented per set as standard |
| 26 to 100 units | Minor | 6 to 9 weeks | Dedicated fixtures justified; process parameters frozen and traceable |
| 100 to 500 units | Negligible | 8 to 12 weeks | Unit price driven by material and labour; a geometry change means new tooling |
| 500 units and above | Absent | 10 to 16 weeks or scheduled | Capacity is booked; the design is closed and the balancing process is audited rather than discussed |
The cost that does not amortise is balancing itself. It is per unit by nature, and it is the line most often compressed when a quote is negotiated down, because the equipment is already paid for and the labour looks like overhead. A supplier who lowers a price by reducing per-unit balancing has not found an efficiency; they have moved the vibration into the aircraft. Ask for tooling and setup cost as a separate line so that the amortisation is visible, and keep balancing priced per unit so that a discount cannot quietly remove it. A configured quotation should separate those two categories.
In-service vibration checks and the intervals that catch drift.
A balanced propeller does not stay balanced, and the vibration budget it was sized against does not stay constant. The intervals below are the ladder we specify for a propulsion set in service, expressed in flight cycles so that use rather than calendar age drives the schedule. Each row carries an acceptance threshold; the thresholds are deliberately expressed as a multiple of the as-delivered baseline, because an absolute limit that ignores the aircraft's own normal vibration level produces both false alarms and missed drift.
| Interval | Check | Acceptance criterion | Action on exceedance |
|---|---|---|---|
| Every flight (pre-flight) | Blade condition sweep and mount play check | No nicks, cracks or tip erosion; no detectable play at the hub | Remove from service before flight; do not rebalance a damaged blade |
| 10 cycles | IMU spectrum capture compared with the delivered baseline | Once-per-revolution peak within 30% of the baseline value | Re-check at the next flight; investigate the mount before rebalancing |
| 50 cycles | Static balance verification on the bench | Within the specified grade for the propeller's mass class | Rebalance or replace the pair; check the adapter runout while the set is off |
| 100 cycles | Hub and adapter runout measurement | Runout within the limit stated in the purchase order | Replace the adapter; a runout fault cannot be balanced out of the propeller |
| 250 cycles | Dynamic balance of the assembled rotating set | Residual couple below the acceptance limit for the airframe | Refit the set and re-measure; sustained exceedance points to the motor or shaft |
The 100-cycle runout row is the one that resolves the largest share of stubborn cases. Vibration that survives two rebalances is usually not a balance problem at all: it is a hub bore or adapter that is out of true, and no amount of weight adjustment will remove a signal that comes from the centre. A field team that measures runout before rebalancing saves the labour of chasing a moving target, and a buyer who writes the runout limit into the order gives them the number to measure against.
The same logic applies to the 10-cycle row: comparing the once-per-revolution peak with the as-delivered baseline is only possible if the baseline was recorded. Ask for the IMU spectrum or the vibration figure at delivery as part of the balance report; a report that states the grade but not the measured value leaves the operator with nothing to trend. Verification and test record practice is described under quality and test records, and the point for the buyer is simply that the baseline is a deliverable.
What the buyer should witness at propeller acceptance.
Acceptance for a propulsion set is usually a certificate, which is the weakest form the process can take. The matrix below is what we run per set, with the method and the record produced. The last column marks the rows that cannot be sampled, and those rows share a property: they describe the individual set that will fly, not the population it came from.
| Acceptance check | Method | Record produced | Can it be sampled |
|---|---|---|---|
| Geometric check (diameter, pitch, blade angles) | Measured against the drawing on a calibrated fixture | Dimensional report per batch | Yes, per batch with a stated plan |
| Static balance per propeller | Balancer reading to the specified grade | Residual imbalance value per unit | No: the value is the deliverable, not the grade |
| Matched-set pairing | Paired by measured mass and residual imbalance vector | Pairing record linking the two serials | No: an unpaired set has no traceable pairing |
| Dynamic balance of the assembled set | Run on a dynamic balancer as a complete rotating assembly | Residual couple value per set | No on the first set; per set thereafter is the minimum |
| Hub and adapter runout | Dial indication at the mounting face and bore | Runout figure per hub and per adapter | No: this is the fault that cannot be balanced out later |
| Mass and inertia per set | Weighed and measured as assembled | Per-set mass and inertia figures | No: these feed the flight controller tuning |
The sampleable row is the geometric one, and it is also the row that matters least once a set is dynamically balanced, because a geometry defect inside tolerance shows up as imbalance anyway. Everything a buyer needs in order to trend vibration in service, and everything needed to prove a set was paired rather than merely boxed together, sits in the non-sampleable rows. A certificate that says the batch met a grade verifies the population and leaves each individual set undocumented.
Bring this matrix into the acceptance conversation before the purchase order. If some rows cannot be met for a given order size, that is a limit of the process worth writing down rather than discovering at the first 100-cycle check with no baseline to compare against. We can work through the matrix against your airframe and propulsion set as part of an engineering enquiry.
Explore custom engineering Back to Blog
EMS Drone manufactures balanced propulsion assemblies under one roof, from component sourcing through production test. If you are specifying for a build, see the full capability set and the tolerances we hold.
Continue Reading
UAV Propeller Selection Guide
Diameter, pitch, blade count and material. The selection methodology that determines what balance grade a given propeller can actually hold.
UAV Propulsion Testing & Validation
Thrust stand, thermal endurance and propeller efficiency measurement, the test program that turns a balance specification into verified performance.
UAV Brushless Motor KV Selection
How motor KV sets the operating RPM range. And therefore the balance grade and blade-pass frequency your propeller specification must reference.
UAV Heavy-Lift Propulsion Design
Large propellers at high disc loading, where imbalance forces scale fastest and dynamic balance becomes non-negotiable.
UAV Motor Topology: BLDC vs PMSM vs PMAC
Torque ripple and harmonic content from the motor side, the other half of the coupled vibration problem this guide addresses.